


Artificial Intelligence and Machine Learning Articles
How to Evaluate LLM Outputs in Production Deployments
AI/ML Skills Gap 2026: Why Companies Can't Find Job-Ready Talent
20 AI/ML Interview Questions Recruiters Can Use Without a Tech Background - Best Guide
How Industry-Backed AI/ML Bootcamps Are Changing the AI/ML Hiring Pipeline - Best Guide 2026
Get In Touch For Details! Request More Information
Search Techniques in AI: The Complete Beginner Guide
Sep 25, 2026 11 Min Read 1154 Views
(Last Updated)
Artificial intelligence often solves problems by searching through possible states, actions, or solutions until it finds one that satisfies a goal. The challenge is not simply finding a solution, but finding it without exploring an impractically large search space.
Search techniques in AI provide systematic strategies for deciding which state to explore next, which paths to ignore, and when a valid or optimal solution has been found. Different methods make different trade-offs between completeness, optimality, execution time, memory usage, and domain knowledge.
Uninformed algorithms such as BFS, DFS, IDDFS, and Uniform Cost Search explore without heuristic guidance. Informed techniques such as A* and Greedy Best First Search use estimates to prioritize promising states. Local search algorithms take a different approach by improving candidate solutions without maintaining complete search paths.
This guide explains the major search techniques in artificial intelligence, how they work, their time and space complexity, heuristic design, real-world applications, and how to choose an appropriate search strategy for a specific AI problem.
Table of contents
- Quick Answer
- Why Search Is Central to AI Problem Solving
- Uninformed Search Techniques
- Informed Search Techniques
- Local Search Techniques
- Heuristic Design: What Makes Search Intelligent
- Comparing All Search Techniques
- What Is State Space Explosion in AI Search?
- What Is Backtracking Search in Artificial Intelligence?
- What Are Constraint Satisfaction Problems in AI Search?
- What Is Adversarial Search in Artificial Intelligence?
- How Do AI Search Techniques Handle Dynamic Environments?
- Benefits of Search Techniques in Artificial Intelligence
- Real-World Applications of Search Techniques in AI
- Navigation and Route Planning
- Game AI
- Robotics and Motion Planning
- Natural Language Processing
- Choosing the Right Search Technique
- Final Thoughts
- FAQs
- What is the difference between informed and uninformed search?
- Why is A considered the best general-purpose search algorithm?
- What makes a heuristic admissible and why does it matter?
- When does hill climbing fail and how does simulated annealing fix it?
- Is beam search used in modern large language models?
Quick Answer
Search techniques in AI are algorithms that explore a state space to find a goal state, an optimal path, or a high-quality solution.
- Uninformed Search: BFS, DFS, IDDFS, and UCS search without heuristic knowledge.
- Informed Search: A* and Greedy Best First Search use heuristic functions to guide exploration.
- Local Search: Hill Climbing, Simulated Annealing, Genetic Algorithms, and Beam Search prioritize solution improvement or memory efficiency.
- Evaluation Criteria: Search algorithms are compared using completeness, optimality, time complexity, and space complexity.
- Selection Rule: The best search technique depends on path costs, heuristic availability, state-space size, memory constraints, and whether an optimal solution is required.
What are Search Techniques in AI?
Search techniques in AI are algorithms used to explore a problem’s state space in order to find a path or solution from an initial state to a goal state. They are fundamental to artificial intelligence problem-solving and include both uninformed methods, which search without prior knowledge, and informed methods, which use heuristics and domain knowledge to guide the search more efficiently.
Why Search Is Central to AI Problem Solving
- Every AI Problem Is a State Space Navigation Problem
A state space is the set of all possible configurations a problem can be in. The initial state is where the system starts. The goal state is what it is trying to reach. Actions define how the system moves between states. The search problem is finding a sequence of actions that connects initial to goal.
This framing applies universally. A puzzle’s state is the current tile arrangement. A route planner’s state is the current location. A game AI’s state is the current board position. Once you see a problem as a state space, search algorithms give you the tools to solve it.
- Search Algorithms Are Evaluated on Four Properties
Completeness means the algorithm is guaranteed to find a solution if one exists. Optimality means the solution found is the best possible. Time complexity measures how many nodes are expanded in the worst case. Space complexity measures how many nodes are stored in memory at once.
No single algorithm wins on all four. Every search technique involves trade-offs between them, and understanding those trade-offs is what makes algorithm selection a skill rather than a lookup.
Read More: Top 20 Graph Algorithms You Must Know
Uninformed Search Techniques
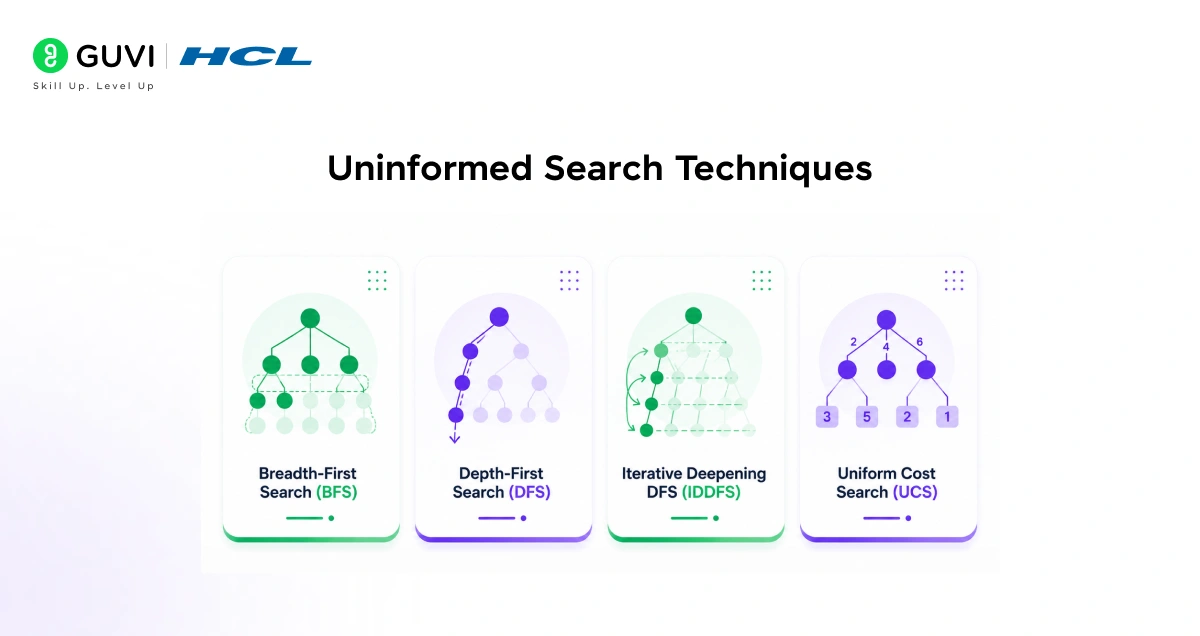
Uninformed search algorithms explore the state space without any domain knowledge about where the goal might be. They treat all unexplored states as equally likely to lead to the goal.
- Breadth-First Search (BFS)
BFS explores all nodes at the current depth before moving deeper, using a queue to always expand the shallowest unexplored node first.
- Complete: Yes | Optimal: Yes (unweighted) | Time: O(b^d) | Space: O(b^d)
- Best for: Shortest paths in unweighted graphs where memory is available and solution depth is shallow.
- Weakness: Memory grows exponentially with depth. A branching factor of 10 at depth 6 means storing one million nodes simultaneously.
- Depth-First Search (DFS)
DFS explores as deep as possible along one path before backtracking, using a stack to always expand the deepest node first.
- Complete: No | Optimal: No | Time: O(b^m) | Space: O(bm)
- Best for: Memory-constrained environments, generating all solutions, problems with deep solution paths.
- Weakness: Can dive deep into irrelevant branches and miss shallow solutions entirely.
- Iterative Deepening DFS (IDDFS)
IDDFS repeatedly runs depth-limited search with increasing depth limits. It combines BFS completeness and optimality with DFS memory efficiency, making it the preferred uninformed algorithm for most practical problems where solution depth is unknown.
- Complete: Yes | Optimal: Yes | Time: O(b^d) | Space: O(bd)
- Uniform Cost Search (UCS)
UCS expands the node with the lowest cumulative path cost rather than the shallowest node, handling weighted graphs correctly. It is Dijkstra’s algorithm in search algorithm form.
- Complete: Yes | Optimal: Yes | Time: O(b^(C*/ε))
- Best for: Weighted graphs where edge costs vary significantly and the lowest cost path is required.
Iterative Deepening Depth-First Search (IDDFS) was popularized by Richard Korf in 1985 and became one of the most important uninformed search strategies for large state spaces. IDDFS combines the optimality guarantees of Breadth-First Search with the low memory usage of Depth-First Search, making it especially effective when the depth of the solution is unknown. This balance between memory efficiency and guaranteed shortest-path discovery is why IDDFS remains widely used in practical search and planning systems.
Informed Search Techniques
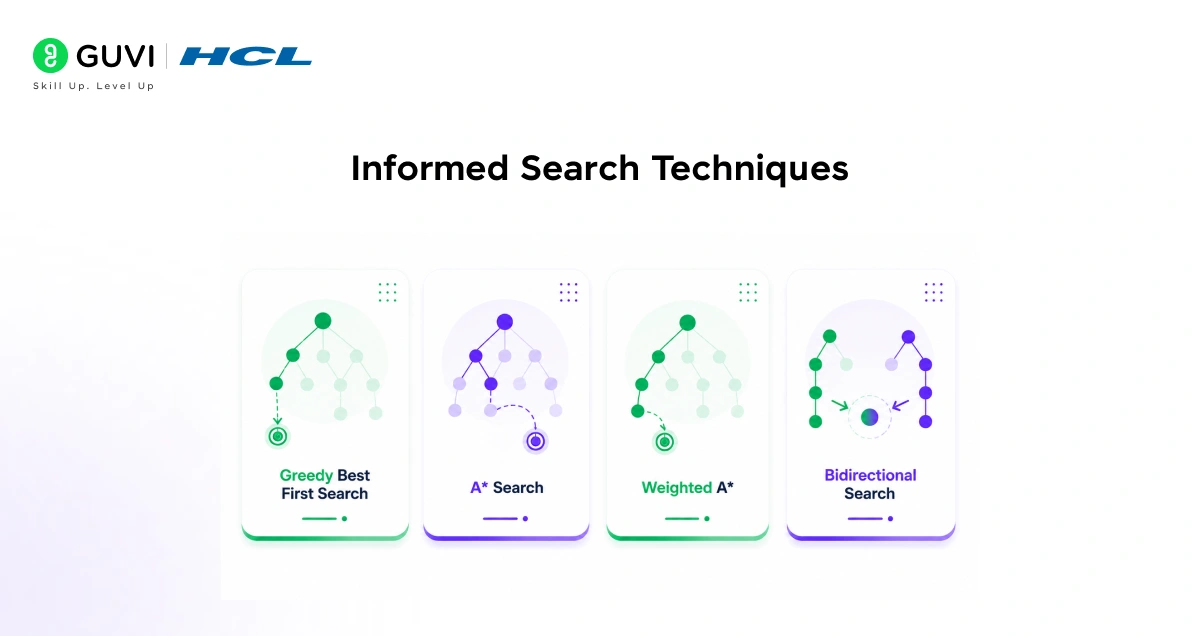
Informed search algorithms use a heuristic function h(n) that estimates the cost from any node to the goal. This domain knowledge allows them to prioritize promising directions and dramatically reduce nodes explored.
- Greedy Best First Search
Always expands the node with the lowest h(n), the node appearing closest to the goal, completely ignoring the cost already paid to reach it.
- Evaluation function: f(n) = h(n)
- Complete: No | Optimal: No | Time: O(b^m) | Space: O(b^m)
- Best for: Real-time scenarios where speed matters more than optimality and a reliable heuristic is available.
- Weakness: Can be misled by heuristics into long suboptimal paths, ignoring expensive terrain already traversed.
- A* Search
A* combines actual path cost g(n) with heuristic estimate h(n), expanding the node with the lowest combined value. It balances what has been paid against what remains to be paid.
- Evaluation function: f(n) = g(n) + h(n)
- Complete: Yes | Optimal: Yes (admissible heuristic) | Time: O(b^d) | Space: O(b^d)
- Best for: Route planning, game pathfinding, robotics, any problem requiring optimal paths with a good heuristic available.
- Critical requirement: The heuristic must be admissible, meaning it never overestimates the true cost to goal.
- Weighted A*
Uses f(n) = g(n) + w·h(n) where w > 1, making the algorithm more greedy. Solutions are guaranteed within a factor of w of optimal, trading exactness for speed. Best for real-time systems where near-optimal solutions found quickly beat exact solutions found slowly.
- Bidirectional Search
Runs simultaneous searches forward from start and backward from goal, meeting in the middle. Reduces time complexity from O(b^d) to O(b^(d/2)), a dramatic improvement for large known state spaces.
A* search was first published in 1968 by Peter Hart, Nils Nilsson, and Bertram Raphael at the Stanford Research Institute. More than five decades later, it remains one of the most widely used pathfinding algorithms in video games, robotics, and navigation systems because of its powerful balance between optimality guarantees and practical efficiency when paired with admissible heuristics.
Local Search Techniques
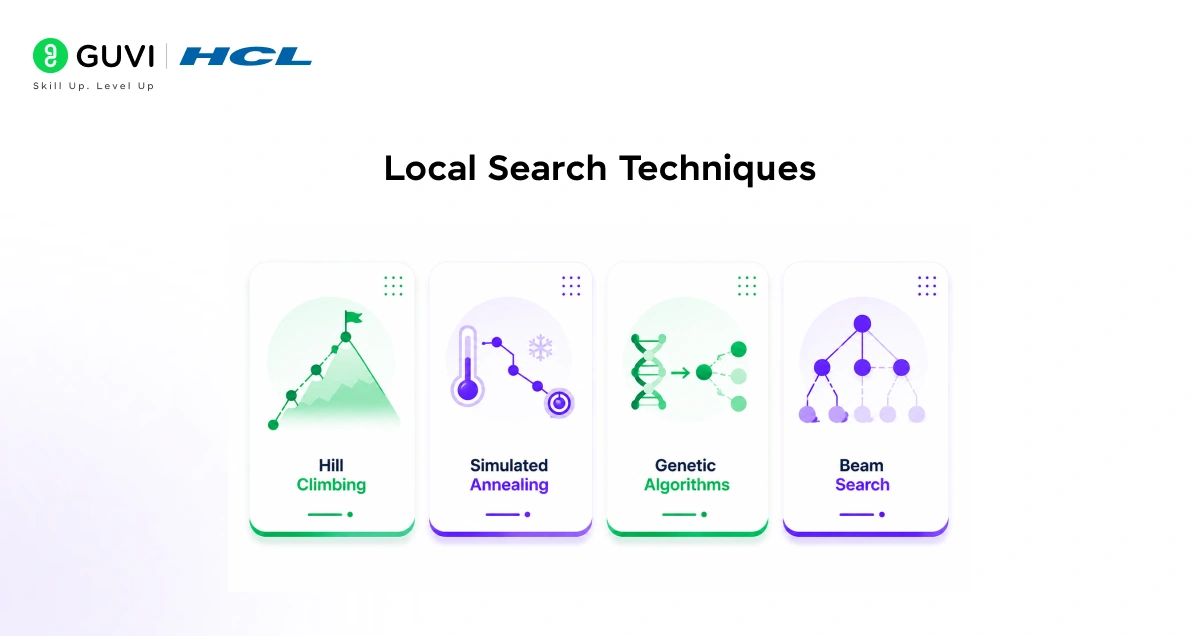
Local search algorithms do not search for a path to the goal. They search for the goal state itself by moving through the state space one step at a time, keeping only the current state in memory rather than maintaining a full frontier.
- Hill Climbing
Starts at an initial state and repeatedly moves to the best neighboring state, stopping when no neighbor improves on the current state.
- Complete: No | Optimal: No | Space: O(1)
- Types: Simple (first better neighbor), steepest ascent (best neighbor), stochastic (random uphill neighbor).
- Core problem: Gets permanently stuck at local maxima with no mechanism to escape.
- Simulated Annealing
Extends hill climbing by occasionally accepting worse states with a probability that decreases over time according to a temperature schedule. High temperature means wide exploration and frequent bad-move acceptance. Low temperature means selective refinement close to pure hill climbing.
Best for: Optimization with many local optima including circuit design, scheduling, and combinatorial problems.
- Genetic Algorithms
Maintains a population of candidate solutions evolved through selection, crossover, and mutation operators inspired by biological evolution. High-fitness individuals reproduce, their representations combine, and random mutations introduce variation across generations.
Best for: Complex optimization with large rugged state spaces where gradient information is unavailable.
Memory-bounded BFS that keeps only the k best nodes at each depth level. Narrower beams are faster but risk missing optimal solutions. GPT-style language models use beam search for text generation because exhaustive search is computationally intractable at vocabulary scale.
Want to strengthen your algorithm fundamentals? Download HCL GUVI’s free DSA eBook and master the data structures and search algorithms powering modern AI systems today.
Heuristic Design: What Makes Search Intelligent
A heuristic function is the difference between informed search that terminates in milliseconds and one that is barely better than blind exploration.
- Admissibility and Consistency
An admissible heuristic never overestimates the true cost to goal. A* requires admissibility to guarantee optimal solutions. A consistent heuristic satisfies the triangle inequality: estimated cost from n to goal never exceeds cost to a neighbor plus estimated cost from that neighbor to goal. Consistency implies admissibility. Most well-designed heuristics are consistent.
- Common Heuristics by Domain
Grid pathfinding: Manhattan distance for four-directional movement, Euclidean distance for free movement, Chebyshev distance for eight-directional movement.
Puzzle solving: Number of misplaced tiles for the 8-puzzle (admissible but weak), sum of Manhattan distances of each tile from its goal position (admissible and significantly stronger).
Route planning: Straight-line distance between current location and destination, admissible because roads are never shorter than straight lines.
- Deriving Heuristics From Relaxed Problems
Solve a relaxed version of the original problem where some constraints are removed. The relaxed solution cost is always admissible for the original because relaxing constraints only makes solutions cheaper or equal in cost. The 8-puzzle Manhattan distance heuristic comes directly from removing the constraint that tiles cannot pass through each other.
Comparing All Search Techniques
| Algorithm | Complete | Optimal | Time | Space | Heuristic |
| BFS | Yes | Yes | O(b^d) | O(b^d) | No |
| DFS | No | No | O(b^m) | O(bm) | No |
| IDDFS | Yes | Yes | O(b^d) | O(bd) | No |
| UCS | Yes | Yes | O(b^C*/ε) | O(b^C*/ε) | No |
| Greedy BFS | No | No | O(b^m) | O(b^m) | Yes |
| A* | Yes | Yes* | O(b^d) | O(b^d) | Yes |
| Hill Climbing | No | No | O(∞) | O(1) | Yes |
| Beam Search | No | No | O(kb) | O(kb) | Yes |
What Is State Space Explosion in AI Search?
State space explosion occurs when the number of possible states grows so rapidly that an AI search algorithm cannot practically explore all of them. It is one of the main computational challenges in search-based artificial intelligence.
If every state generates b successor states and the solution exists at depth d, the potential search space can grow approximately as:
O(b^d)
For example, with a branching factor of 10:
- Depth 1: 10 states
- Depth 2: 100 states
- Depth 4: 10,000 states
- Depth 6: 1,000,000 states
This exponential growth explains why exhaustive search becomes impractical even for apparently moderate problems.
AI systems reduce state space explosion through techniques such as:
- Heuristic functions
- Alpha-beta pruning
- Duplicate-state detection
- Constraint propagation
- Beam-width limits
- Abstraction and hierarchical search
- Bidirectional search
- Branch-and-bound techniques
The objective is not always to reduce the theoretical state space itself. Instead, an efficient search strategy attempts to avoid expanding states that are unlikely to contribute to a useful solution.
State space explosion is especially important in game playing, automated planning, robotics, scheduling, and combinatorial optimization.
What Is Backtracking Search in Artificial Intelligence?
Backtracking is a systematic search technique that builds a solution incrementally and abandons a partial solution as soon as it determines that the current path cannot produce a valid result.
The basic process is:
Choose → Test → Continue → Detect Failure → Undo → Try Another Choice
Consider a variable assignment problem:
A = 1
B = 3
C = ?
If assigning C = 2 violates a constraint, the algorithm does not continue exploring descendants of that assignment.
Instead, it returns to an earlier decision:
C = 2 → Invalid
     ↓
Backtrack
     ↓
Try C = 4
Backtracking is closely related to depth-first exploration because it follows one candidate solution deeply before returning to alternative choices.
However, its main strength is early rejection of invalid partial solutions.
Backtracking is commonly useful for:
- N-Queens
- Sudoku
- Graph coloring
- Scheduling
- Permutation problems
- Constraint Satisfaction Problems
Its performance can be improved using techniques such as variable ordering, value ordering, forward checking, and constraint propagation.
What Are Constraint Satisfaction Problems in AI Search?
A Constraint Satisfaction Problem, or CSP, is an AI search problem defined by variables, possible values for those variables, and constraints that determine which combinations are valid.
A CSP contains three main components:
Variables:X1, X2, X3 ... Xn
Domains:
Possible values each variable can take.
Constraints:
Rules restricting which combinations of values are allowed.
For example, a simple map-coloring problem may define:
Variables:
A, B, C

Domain:
{Red, Green, Blue}

Constraint:
Adjacent regions cannot have the same color.
The objective is not necessarily to find a path from one location to another. It is to find a complete assignment that satisfies every constraint.
Common CSP-solving techniques include:
- Backtracking search
- Forward checking
- Constraint propagation
- Arc consistency
- Minimum Remaining Values
- Degree heuristic
- Least Constraining Value
CSP search is important because many real-world AI problems can be represented naturally as constraints, including:
- Employee scheduling
- Timetabling
- Resource allocation
- Configuration problems
- Planning
- Puzzle solving
Good constraint propagation can eliminate impossible values before full search begins, substantially reducing the number of assignments that need to be explored.
What Is Adversarial Search in Artificial Intelligence?
Adversarial search is used when an AI agent searches for the best action while another agent actively attempts to produce an opposing outcome.
Unlike ordinary pathfinding, where the environment itself is not strategically fighting the search algorithm, adversarial problems contain competing decision-makers.
Board games provide a common example.
A game tree may look like:
Current State
      ↓
AI Moves
      ↓
Opponent Moves
      ↓
AI Moves
      ↓
Future Game States
The Minimax algorithm evaluates this tree by assuming:
- The maximizing player chooses the highest-value move.
- The minimizing opponent chooses the lowest-value response.
For large game trees, exploring every possible move becomes expensive.
Alpha-beta pruning improves Minimax by eliminating branches that cannot affect the final decision.
For example, if the algorithm already knows that one branch guarantees a score of 8, it may avoid fully evaluating another branch once that branch is proven incapable of producing a better decision.

Adversarial search concepts are used in:
- Chess
- Checkers
- Tic-tac-toe
- Strategy games
- Multi-agent decision systems
This makes adversarial search fundamentally different from BFS, UCS, or A*, because the future state depends not only on the AI’s actions but also on the strategic actions of an opponent.
How Do AI Search Techniques Handle Dynamic Environments?
Dynamic search is required when states, obstacles, or action costs can change while an AI agent is executing its plan.
Classical search often assumes that the search space remains stable during computation.
A route may initially be:
Start → A → B → C → GoalHowever, the environment may later change:
B → C = BlockedThe original path is no longer valid.
The AI system must then update its internal representation and calculate another route.
A basic approach is:
Detect Change → Update State Space → Search Again → Execute New Plan
Repeatedly restarting a complete search can become expensive in large environments. Incremental search algorithms therefore attempt to reuse information from earlier searches.
Examples include:
- Lifelong Planning A*
- D*
- D* Lite
- Incremental heuristic search
Dynamic search is particularly important for:
- Autonomous robots
- Warehouse navigation
- Self-driving systems
- Changing traffic networks
- Game environments
- Network routing
- Real-time planning
The important distinction is that a static search algorithm solves a fixed problem representation, while dynamic search must continuously adapt its solution when the underlying state space or transition costs change.
Benefits of Search Techniques in Artificial Intelligence
- Systematic State-Space Exploration: Search algorithms define which state should be expanded next instead of exploring possibilities randomly. BFS expands by depth, UCS prioritizes accumulated path cost, while A* combines path cost with heuristic guidance.
- Finding Optimal or Lowest-Cost Solutions: Algorithms such as UCS and A* can identify minimum-cost paths when their required conditions are satisfied. This is useful when edge costs represent distance, travel time, energy, risk, or another measurable cost. Pasted text
- Reduced Search Through Heuristics: Informed techniques use a heuristic
h(n)to estimate how promising a state is. A useful heuristic can reduce unnecessary node expansion compared with uninformed exploration, making large search spaces more manageable. Pasted text - Different Algorithms for Different Resource Constraints: Search techniques offer explicit trade-offs between time and memory. BFS may require substantial memory, while DFS and IDDFS store far fewer states. Beam Search can explicitly restrict the number of candidates retained at each level. Pasted text
- Completeness and Optimality Guarantees: Some algorithms can guarantee that a solution will be found when one exists, while others can additionally guarantee an optimal solution under defined conditions. These properties allow developers to choose an algorithm based on the reliability requirements of the application. Pasted text
- Supports Both Pathfinding and Optimization: Graph-search techniques such as BFS, UCS, and A* focus on finding paths through state spaces. Local search methods such as Hill Climbing and Simulated Annealing instead optimize candidate states when the complete path is less important than the final solution. Pasted text
- Handles Large Combinatorial Problems: Methods such as heuristic search, pruning, beam search, and population-based optimization reduce the need for exhaustive enumeration when the number of possible states grows exponentially.
- Works Across Multiple AI Domains: The same search principles can support route planning, game decision-making, robotic motion planning, and sequence-generation problems because each can be represented as states, transitions, goals, or candidate solutions. Pasted text
- Provides Clear Algorithm-Selection Trade-offs: Developers can choose BFS for equal-cost shallow searches, UCS for variable-cost paths, A* when a useful heuristic is available, or local search when memory and optimization matter more than complete path reconstruction. Pasted text
Real-World Applications of Search Techniques in AI
Search techniques are used whenever an AI system must explore many possible states, actions, routes, or output sequences and select a feasible or high-quality solution.
1. Navigation and Route Planning
Navigation systems represent road networks as weighted graphs, where intersections or locations become nodes and road segments become edges.
Edge weights can represent:
- Travel distance
- Estimated travel time
- Toll cost
- Traffic conditions
- Road restrictions
- Turn penalties
Algorithms such as A* can prioritize routes using:\[ f(n) = g(n) + h(n) \]
Here, g(n) represents the actual travel cost accumulated so far, while h(n) estimates the remaining cost to the destination.
For geographic routing, a straight-line or geographic distance estimate can provide heuristic guidance. Large routing systems may also use bidirectional search, hierarchical routing, preprocessing, and graph partitioning to reduce the number of road-network nodes examined.
This allows route planners to search extremely large transportation graphs without evaluating every possible road.
2. Game AI
Search algorithms perform different roles depending on the type of game.
In board games such as chess, the current board configuration becomes a state, while legal moves generate successor states. A game tree can therefore contain millions of possible future positions.
Algorithms such as Minimax evaluate competing move sequences, while alpha-beta pruning eliminates branches that cannot influence the final decision.
For example:
Current Position
      ↓
Possible Moves
      ↓
Opponent Responses
      ↓
Future Positions
      ↓
Evaluation Function
In navigation-based games, NPC movement is commonly formulated as a graph-search problem.
A* can evaluate:
- Grid cells
- Navigation-mesh polygons
- Waypoints
- Terrain costs
- Movement restrictions
- Obstacles
A game may assign different costs to terrain:
Road = 1
Grass = 2
Mud = 5
Blocked Cell = ∞
The search therefore finds the lowest-cost traversable path, rather than simply the geometrically shortest route.
3. Robotics and Motion Planning
Robotic path planning is more complex because the search state may include much more than an (x, y) position.
A mobile robot state could contain:
(x, y, orientation)A robotic arm may require a configuration such as:
(θ1, θ2, θ3, θ4, θ5, θ6)where each θ represents a joint angle.
These variables create a configuration space, often called C-space, containing the robot’s possible physical configurations.
Search algorithms must identify a sequence of valid states that:
- Avoids collisions
- Respects joint limits
- Follows movement constraints
- Reaches the target configuration
- Minimizes distance, time, energy, or another cost
Robotic systems may discretize continuous spaces into occupancy grids, state lattices, navigation graphs, or motion primitives before applying graph-search techniques.
When sensor readings reveal new obstacles, the system may also need to replan instead of relying permanently on the original route.
4. Natural Language Processing
Natural language generation can also be viewed as a search problem.
At every decoding step, a language model assigns probabilities to possible next tokens.
For example:
"The"
 ↓
"cat"  0.31
"car"  0.18
"man"  0.14
...
Choosing only the highest-probability token at every step is called greedy decoding, but the locally best token does not necessarily produce the highest-scoring complete sequence.
Beam search keeps the best k partial sequences instead.
For a beam width of 3:
Step 1:
A
B
C

Step 2:
A → X
B → Y
C → Z

Keep best 3 sequences
        ↓
Expand again
The process continues until an end condition is reached.
Beam width controls the trade-off:
Larger k → More candidate sequences + Higher computation
Smaller k → Faster decoding + Greater risk of discarding a better sequence
Beam search has historically been used in tasks such as machine translation, speech recognition, and sequence generation, where exhaustively examining every possible token sequence is computationally impossible.
Choosing the Right Search Technique
Choosing a search algorithm depends on the graph structure, edge costs, expected solution depth, available memory, heuristic quality, and whether completeness or optimality is required.
- Breadth-First Search (BFS): Use BFS when the graph is unweighted or every action has the same cost and the objective is to find the shallowest solution. It is complete and returns a shortest path under equal step costs, but its
O(b^d)memory requirement makes it expensive when the branching factor or solution depth is large. - Iterative Deepening DFS (IDDFS): Use IDDFS when the solution depth is unknown, step costs are equal, and memory is limited. It repeatedly performs depth-limited DFS while increasing the depth bound, providing BFS-like completeness and optimality with approximately
O(bd)space instead of storing an entire BFS frontier. - Uniform Cost Search (UCS): Use UCS when edges have different non-negative costs and the objective is the minimum-total-cost path rather than the path containing the fewest edges. Its priority queue expands the state with the lowest accumulated path cost
g(n). It is particularly useful when no reliable heuristic is available. - A Search:* Use A* when the problem has non-negative path costs, an informative heuristic, and a requirement for an optimal path. It evaluates
f(n) = g(n) + h(n), combining accumulated cost with estimated remaining cost. With an admissible heuristic, and commonly a consistent heuristic for graph search, A* can explore substantially fewer states than UCS while preserving optimality guarantees. - Greedy Best First Search: Use Greedy Best First Search when reaching a promising goal quickly matters more than guaranteeing the cheapest path. It ranks states only by
h(n), ignoring accumulated cost. This can reduce exploration with a strong heuristic, but the resulting path may be suboptimal or heavily affected by misleading heuristic estimates. - Hill Climbing: Use Hill Climbing for optimization problems where only the final state matters and storing complete search paths is unnecessary. It repeatedly moves to a better neighbouring state and requires very little memory. However, it can become trapped at local maxima, plateaus, or ridges.
- Simulated Annealing: Use Simulated Annealing when the search space contains many local optima and Hill Climbing becomes trapped too easily. It occasionally accepts worse moves according to a temperature-controlled probability, allowing broader exploration early in the search before gradually becoming more selective.
- Genetic Algorithms: Use Genetic Algorithms when the problem has a very large, discontinuous, combinatorial, or non-differentiable search space where a single-path search is unsuitable. They maintain a population of candidate solutions and improve them through selection, crossover, and mutation. They are useful when good approximate solutions matter more than guaranteed optimality.
- Beam Search: Use Beam Search when exhaustive expansion is computationally impossible and memory must be explicitly bounded. It keeps only the best
kcandidate states at each stage. A larger beam width improves exploration but increases computation and memory, while a smaller beam is faster but increases the chance of discarding the path leading to the best solution.
To learn more about search techniques in AI and how intelligent systems find solutions to complex problems, do not miss the chance to enroll in HCL GUVI’s Intel & IITM Pravartak Certified Artificial Intelligence & Machine Learning course. Endorsed with Intel certification, this course adds a globally recognized credential to your resume, a powerful edge that sets you apart in the competitive AI job market.
Final Thoughts
Search techniques remain a fundamental part of artificial intelligence because many AI tasks can be represented as navigating a state space toward a goal. The main challenge is deciding which possibilities deserve exploration without consuming unnecessary time or memory.
Uninformed search provides systematic exploration without domain guidance. Informed search uses heuristics to reduce unnecessary node expansion, while local search focuses on improving candidate solutions when storing complete paths is impractical. The underlying implementation also depends on factors such as duplicate-state handling, frontier management, observability, and whether the agent searches before acting or while interacting with its environment.
The right search algorithm therefore depends on the problem structure, edge costs, search-space size, heuristic quality, memory constraints, observability, and required solution guarantees. Understanding these factors makes it easier to choose an AI search technique based on technical requirements rather than simply selecting the most familiar algorithm.
FAQs
1. What is the difference between informed and uninformed search?
Uninformed search uses only graph structure with no domain knowledge, exploring blindly. Informed search uses a heuristic function estimating distance to goal, allowing the algorithm to prioritize promising directions and explore far fewer nodes.
2. Why is A considered the best general-purpose search algorithm?
A* is complete and optimal under admissible heuristics while being dramatically more efficient than uninformed methods on most practical problems. No other algorithm matches this combination of guarantees and practical efficiency, which is why it has dominated pathfinding for over five decades.
3. What makes a heuristic admissible and why does it matter?
A heuristic is admissible if it never overestimates the true cost to goal. Admissibility matters because A* relies on it to guarantee optimal solutions. An inadmissible heuristic can cause A* to skip the optimal path in favor of one that looks cheaper based on the inflated estimate.
4. When does hill climbing fail and how does simulated annealing fix it?
Hill climbing permanently stops at local maxima where no neighbor improves on current state, even when better states exist elsewhere. Simulated annealing fixes this by occasionally accepting worse states with decreasing probability over time, allowing escape from local optima through controlled exploration.
5. Is beam search used in modern large language models?
Yes. Beam search is the standard decoding strategy for language models, keeping the k most probable partial sequences at each generation step rather than committing greedily to one token. This produces better outputs than greedy decoding while remaining tractable compared to exhaustive search across the full vocabulary.
Success Stories

About the Author
Vaishali
I'm a seasoned writer with four years of experience across technical, non-technical, and just about every genre or niche you can imagine. Adaptable and curious, I enjoy exploring new topics and making information engaging and easy to understand. Fueled by a steady stream of tea, I approach each project with creativity, reliability, and genuine enthusiasm for storytelling.
View all posts by Vaishali
Connect with me @



Did you enjoy this article?